5 Fundamental Concepts of Solid Mechanics
This section is adapted from chapter 1 of Introduction to Solid Mechanics - An Integrated Approach by Lubliner and Papadopoulos (Lubliner and Papadopoulos 2017).
- Mechanics
- Mechanics, as a scientific discipline, is the study of the behavior of bodies subject to forces and displacements (and, to some extent, heating and cooling).
- Solid Mechanics
- Solid mechanics is the branch of mechanics dealing specifically with solid bodies.
- Body
- A body, for the purpose of mechanics, is a portion of matter that, at a given moment in time, occupies a certain region in space.
- Particle
- If the region occupied by the body can be idealized as being of negligible extent (and thus reducible to a point), the body is called a particle.
- Finite Body
- A body that is not reducible to a point is called a finite body.
- Continuum
- A finite body occupying a connected region every portion of which contains some matter is called a continuous body or, simply, a continuum.
- Material Points
- At any point in a region occupied by a continuum, the matter in its immediate (infinitesimal) neighborhood can also be thought of as constituting a particle, and we may thus speak of the particles (also called material points) of a continuum.
- Displacement
- A body is said to undergo a displacement when some or all of its particles are moved to occupy different positions in space.
- Configuration
- The correspondence between the particles and the positions occupied by them at a given time is known as the body’s configuration.
- Deformation
- The displacement of a body is said to be rigid if the distances between all pairs of particles are the same in any two configurations. Otherwise, the body is said to undergo deformation.
- Kinematics
- The branch of mechanics dealing with the displacement and motion of bodies is called kinematics.
- Force
- Forces are interactions between bodies that cause them to move, and more specifically to accelerate, relative to each other (unless prevented from doing so by other forces).
5.1 Galileo, Kepler, Newton
5.1.1 Gravitational force
All bodies on or near the earth are subject to the earth’s gravitational force and, as shown by Galileo in his famous experiments, will fall toward the center of the earth (unless prevented from doing so by other forces) with the same acceleration; the magnitude of this acceleration is denoted by \(g\).
Historical Perspective: Galileo Galilei (1564–1642)
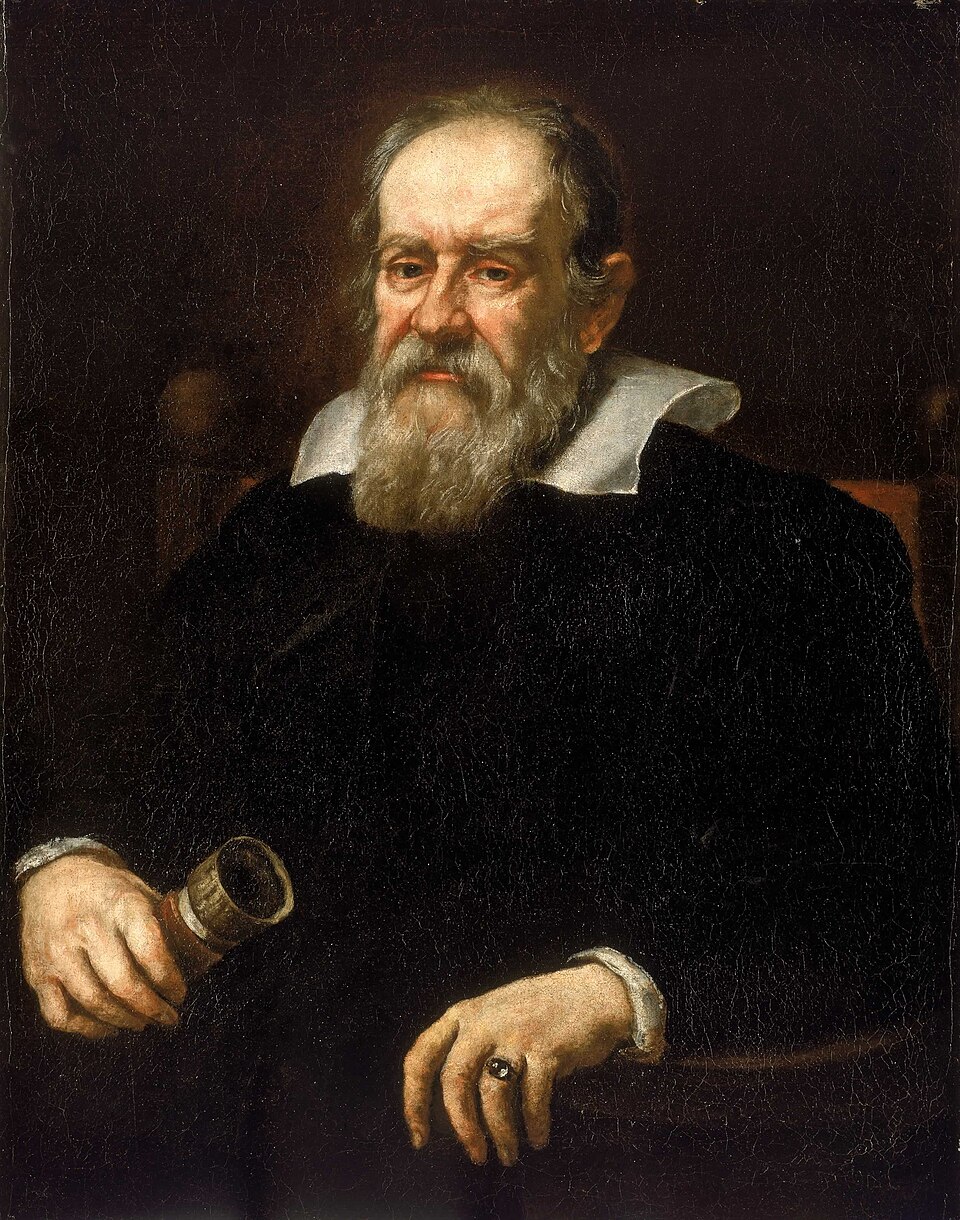
Italian astronomer, physicist, and engineer, often called the father of observational astronomy and of the modern scientific method. His experiments on falling bodies and inclined planes were the first systematic study of kinematics, and his advocacy of a heliocentric solar system brought him into famous conflict with the Church.
It was later shown by Newton, on the basis of Kepler’s laws of planetary motion, that the magnitude of the acceleration (with respect to a frame of reference based on the “fixed” stars) due to gravitational force between any two bodies (idealized as particles) is inversely proportional to the square of the distance between them, and for each body it is proportional to the quantity of matter (or mass) of the other body. The product of mass and acceleration is therefore equal and opposite for the two bodies and may be identified with the force exerted on each body by the other.
Historical Perspective: Isaac Newton (1642–1727)
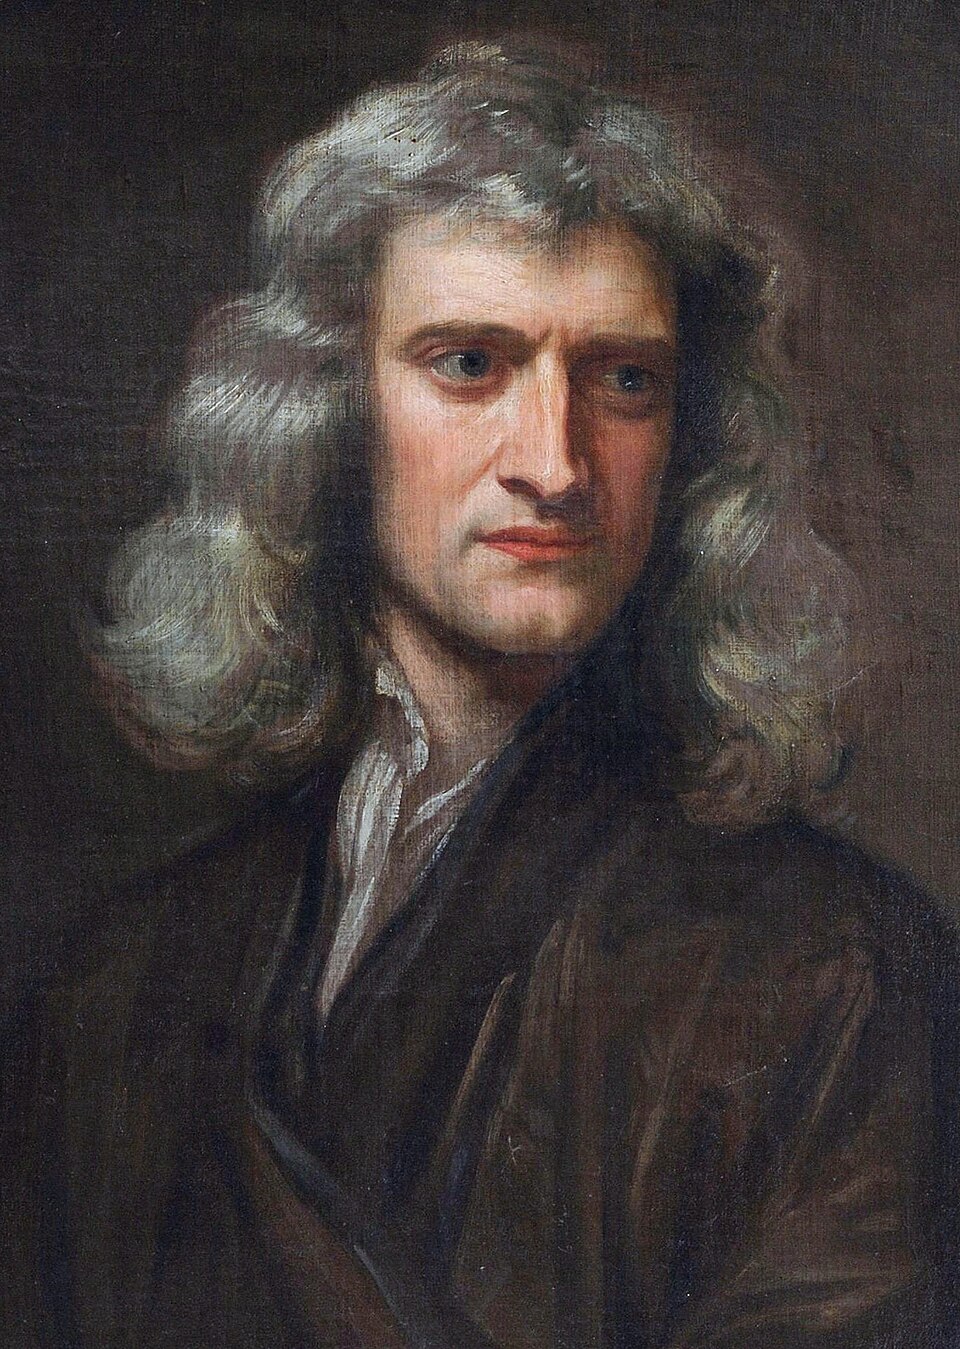
English mathematician and physicist. Building on Galileo’s and Kepler’s work, Newton’s 1687 Philosophiæ Naturalis Principia Mathematica established the three laws of motion and the law of universal gravitation, unifying the mechanics of falling bodies on Earth with the motion of the planets for the first time.
5.1.2 Equilibrium
If a body’s acceleration is zero, then it is at rest or in a uniform motion. In this case, the forces is said to be in equilibrium. The study of equilibrium is known as statics and constitutes one of the main subjects of this book. Traditionally, statics deals only (or at least primarily) with rigid bodies, while deformable bodies are studied in courses historically called strength of materials (or, more recently, mechanics of materials). In this book (Lubliner and Papadopoulos 2017), the statics of rigid and deformable solid bodies will be studied in an integrated manner.